The platform
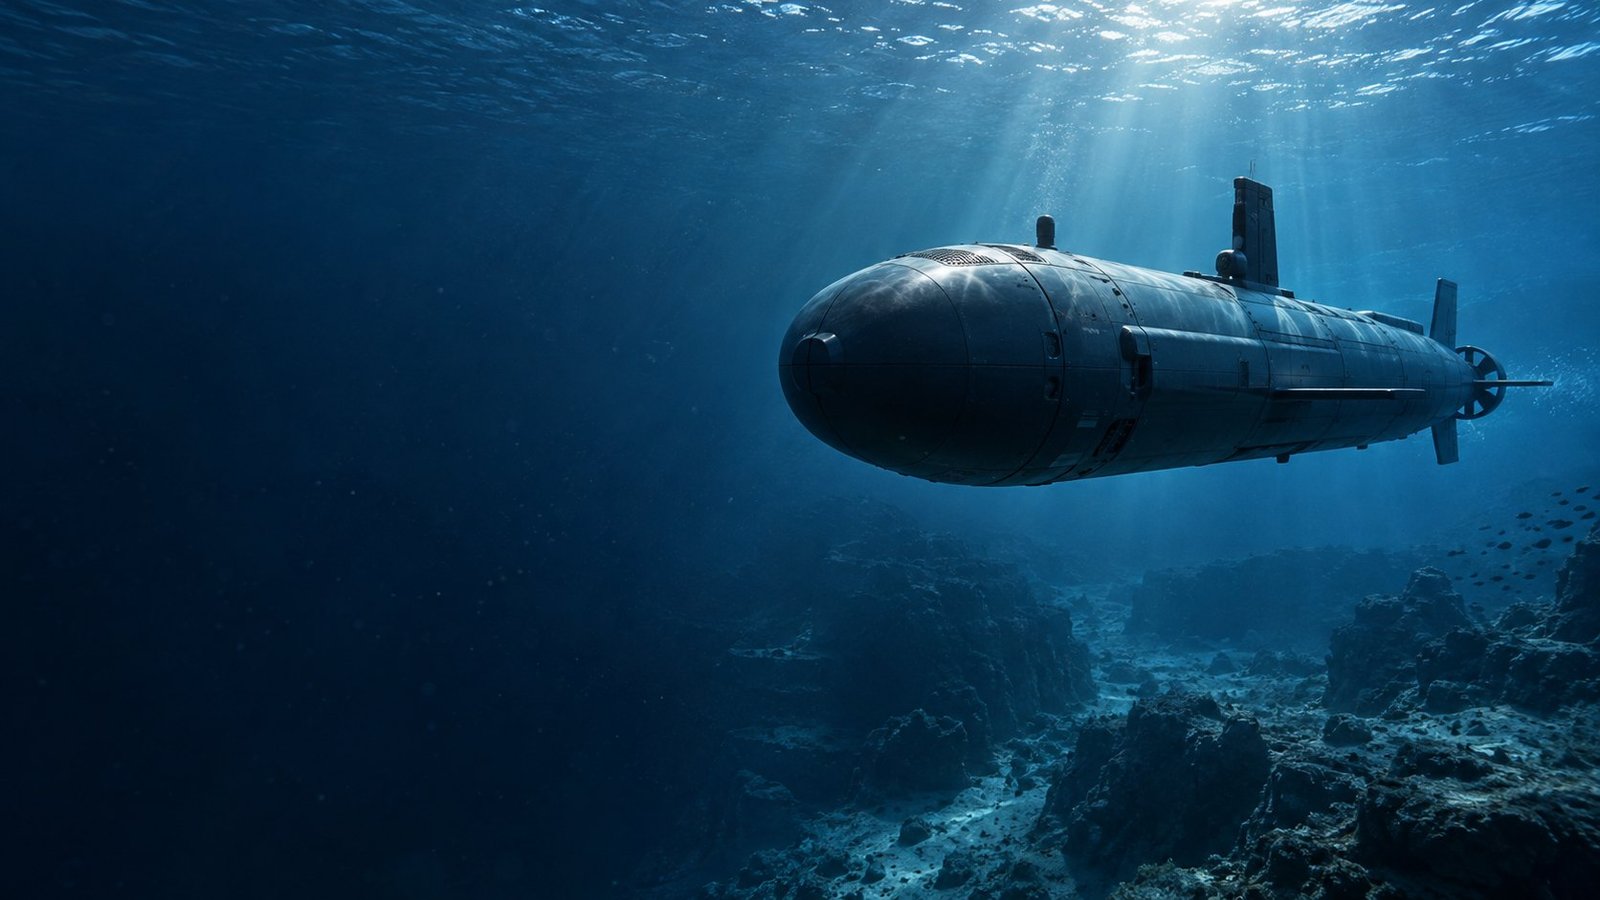
Extra-Large Unmanned Underwater Vehicle
Autonomous underwater mothership
What it is
Built as a force multiplier, not only a single-mission vehicle.
Conventional extra-large vehicles are built around a single mission: reconnaissance, or payload delivery. This platform is not only a single mission vehicle, but a force multiplier for distributed operations. It navigates autonomously to a designated area and deploys mission assets according to a pre-programmed plan, extending situational awareness across a maritime zone without continuously exposing high-value manned platforms.
The development approach is deliberately prototype-first. Rather than pursuing a fully optimised system from the outset, the programme is structured to reach the field early, validate autonomy in real conditions, and iterate from operational data. Key design decisions - a flooded architecture, a conservative hydrodynamic profile, proven battery technology - reduce integration complexity and shorten the distance to deployment.
The architecture remains modular and extensible. Payload systems, energy configurations and mission profiles can be upgraded progressively, without a complete redesign.
Concept of operations
From mission preparation to autonomous execution.
Long-duration deployment, minimal human intervention, repeatable execution.
Configure & Deploy
Navigate & Execute
Recover, Review & Re-task
Specifications
Published to the class. Detailed on request.
Public figures describe the vehicle class and role. Dimensional, depth, endurance and payload parameters are released against a named request.
- Vehicle class
- Extra-Large Unmanned Underwater Vehicle (XLUUV)
- Primary role
- Autonomous underwater mothership
- Configuration
- Flooded, modular architecture
- Scale
- 12 m class Optimised for transportability and deployment
- Endurance
- Multi-week Mission profile dependent
- Mission control
- Fully autonomous
Detailed specification
Dimensional, depth, endurance, energy and payload figures are released against a named request. 13 further parameters are available in the technical specification pack.
Request a technical briefing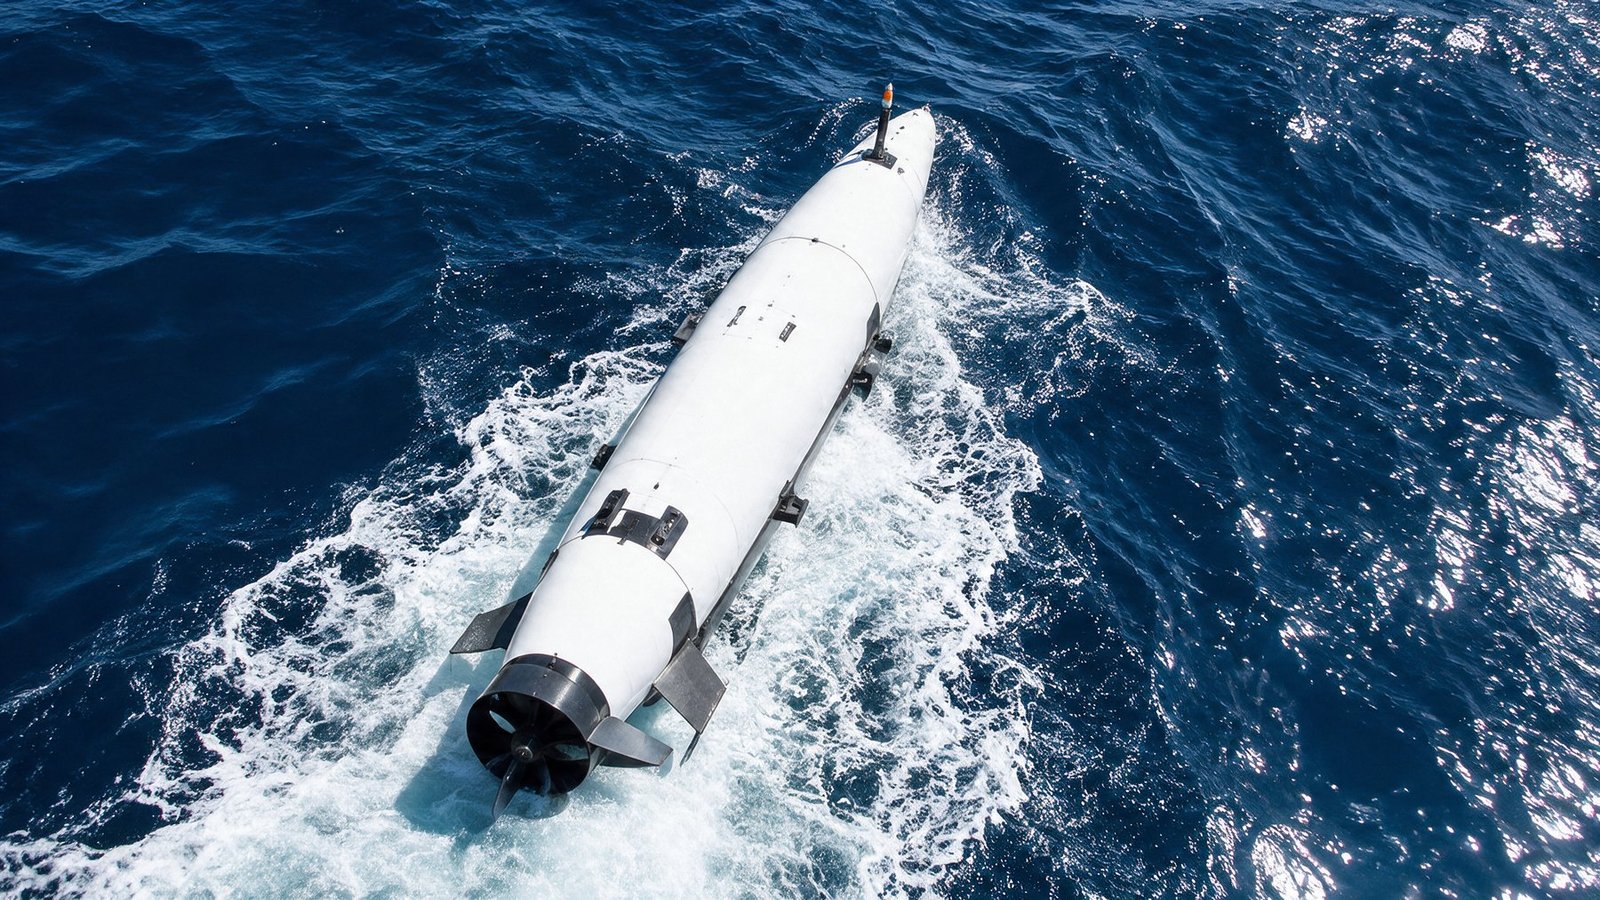
Next
Assessing this platform for a programme?
Let's take it forward, tell us the requirements.